Currency
|

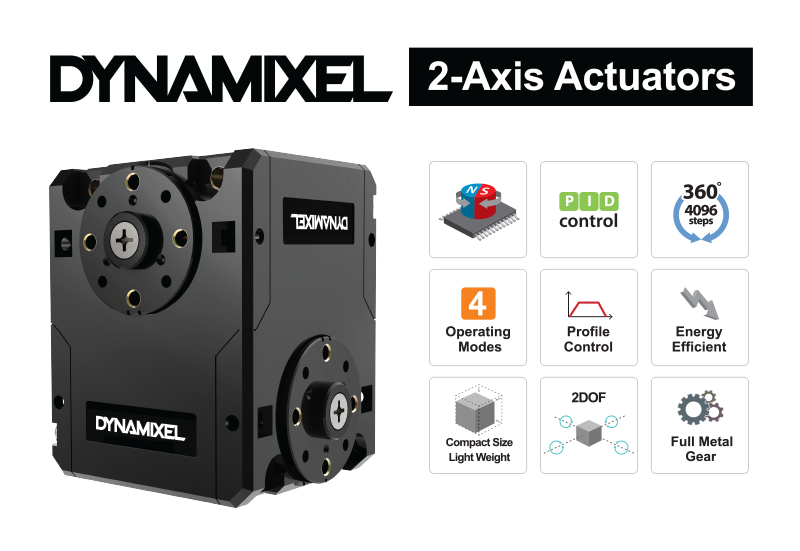
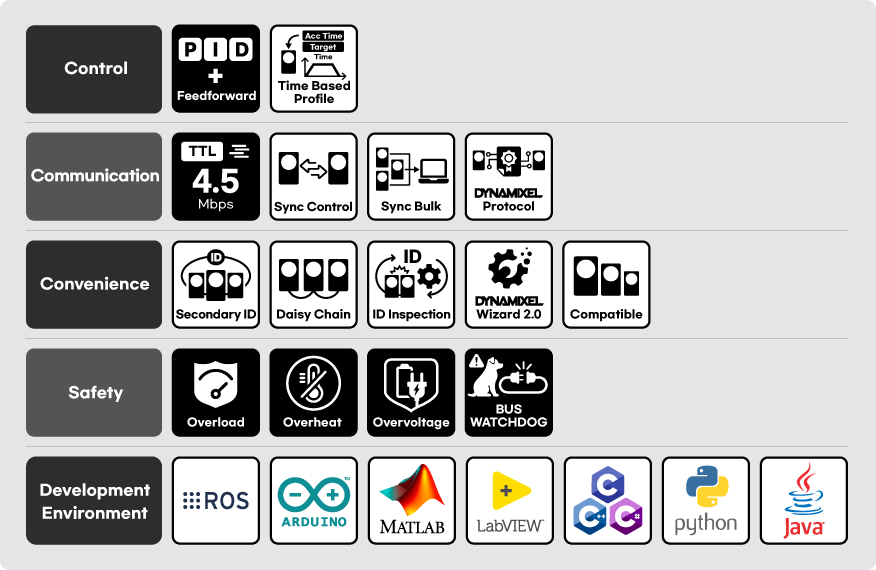
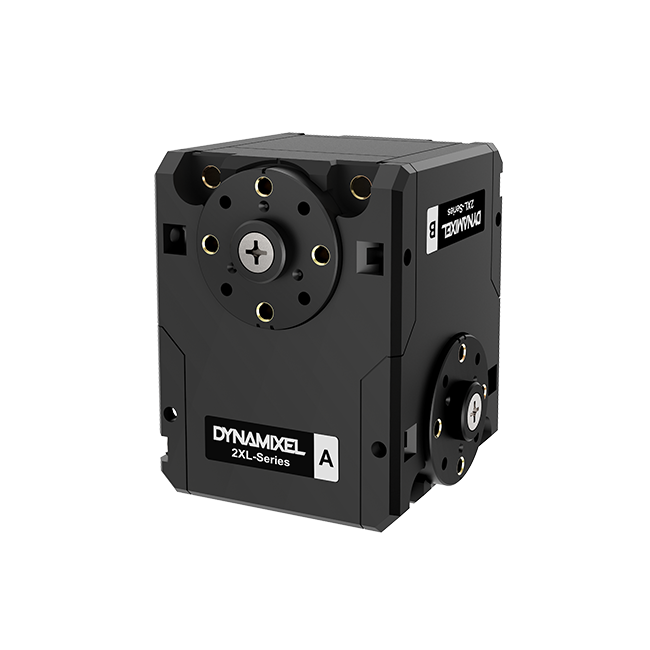
DYNAMIXEL is a robot exclusive smart actuator with fully integrated DC Motor + Controller + Driver + Sensor + Reduction Gear + Network in one DC servo module.
The DYNAMIXEL 2XL series can control two axis with a single module, so it can be effectively applied to robot`s neck, shoulder, hip, wrist, and ankle. The 2XL series adopts new features that allow 360 degrees control mode with its contactless magnetic encoder and hollow back case assembly structure and Metal gear (Powder Metallurgy) is used for high durability. High compatibility with XL430, XM430, XH430.
1. Various Operating Modes
(Velocity Control, Position Control, Extended Position Control, PWM Control)
2. Profile Control for Smooth Motion Planning
3. Hollow Back Case Minimizes Cable Stress
4. Easy and Simple Assembly Structure
5. Energy Saving with Reduced Current
| Item Name | Quantity | Description |
|---|---|---|
| 2XL430-W250-T | 1 | DYNAMIXEL |
| Robot Cable-X3P 180mm | 1 | TTL 3p Cable(JST-JST) |
| Bolt M2.5x5 | 10 | For frame assembly |
| Bolt M2x5 | 10 | For horn & frame assembly |
* Idler Set(HN11-I101 Set) for assembling hinge frames are not included.
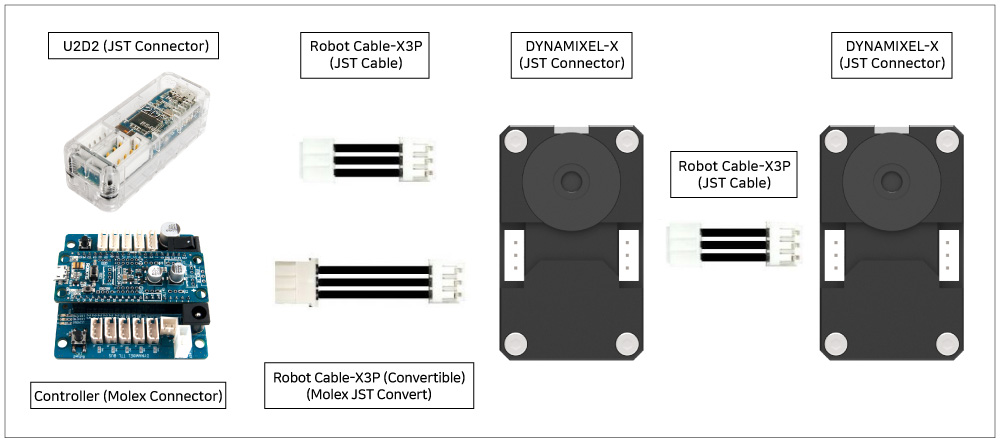
DYNAMIXEL-X Series cable assembly through hollow case
Organize the entangled cable before assembling the back case.
Do not assemble the back case with entangled cable. The entangled cable can be squashed by the case and cause communication error.
The DYNAMIXEL-X Series adopted a new gold-plated JST connector for secure and reliable communication.
The connector used for the previous Dynamixel is Molex.
Molex-JST conversion cable is not included with the purchase of 2XL430 Dynamixel, so you must purchase Molex-JST conversion cable separately to connect to the existing controller (OpenCM 485 expansion board, USB2Dynamixel).
| Model Name | 2XL430-W250-T | |
|---|---|---|
| Series | DYNAMIXEL X | |
| MCU | ARM Cortex-M3 (72 [Mhz], 32 [bit]) | |
| Input Voltage | Min. [V] | 6.5 |
| Recommended [V] | 11.1 | |
| Max. [V] | 12.0 | |
| Performance Characteristics | Voltage [V] | 11.1 |
| Stall Torque [N·m] | 1.40 | |
| Stall Current [A] | 1.3 | |
| No Load Speed [rpm] | 57.0 | |
| No Load Current [A] | 0.05 | |
| Continuous Operation | Voltage [V] | - |
| Torque [N·m] | - | |
| Speed [rpm] | - | |
| Current [A] | - | |
| Resolution | Resolution [deg/pulse] | 0.0879000000 |
| Step [pulse/rev] | 4,096 | |
| Angle [degree] | 360 | |
| Position Sensor | Contactless absolute encoder (12 [bit], 360 [deg]) Maker : ams(www.ams.com), Part No : AS5045 | |
| Operating Temperature | Min. [°C] | -5 |
| Max. [°C] | 72 | |
| Motor | Cored | |
| Baud Rate | Min. [bps] | 9,600 |
| Max. [bps] | 4,500,000 | |
| Control Algorithm | PID | |
| Gear Type | Spur | |
| Gear Material | Metal | |
| Case Material | Engineering Plastic | |
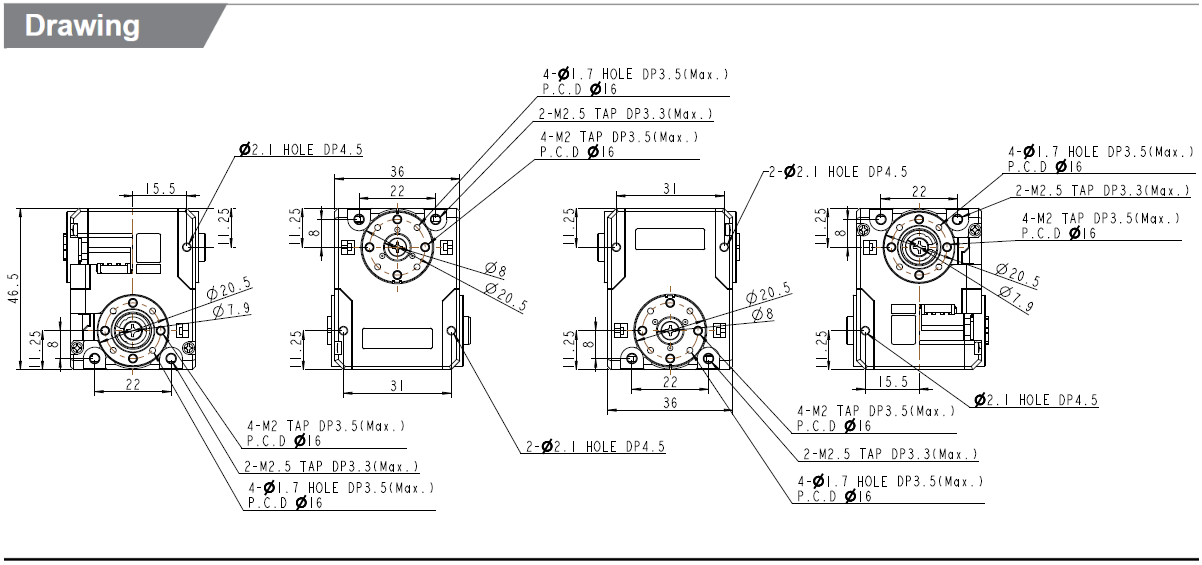
| Dimensions (WⅹHⅹD) [mm] | 36 x 46.5 x 36 | |
| Dimensions (WⅹHⅹD) [inch] | 1.4 x 1.83 x 1.41 | |
| Weight [g] | 98.00 | |
| Weight [oz] | 3.46 | |
| Gear Ratio | 257.4 : 1 | |
| Backlash [arcmin] | - | |
| Backlash [deg] | - | |
| Command Signal | Digital Packet | |
| Protocol Type | Half duplex Asynchronous Serial Communication (8bit, 1stop, No Parity) | |
| Link (Physical) | TTL Level Multidrop Bus | |
| ID | 0 ~ 253 | |
| Feedback | Position, Velocity, Load, Realtime tick, Trajectory, Temperature, Input Voltage, etc | |
| Protocol version | Protocol 1.0 Protocol 2.0(Default) | |
| Operating Mode / Angle | Velocity Control mode:Endless turn Position Control Mode:360 [deg] Extended Position Control Mode:±256 [rev] PWM Control Mode:Endless turn | |
| Output [W] | - | |
| Standby Current [mA] | 49 | |
| Manufacturer | Robotis |
|---|