Currency
|

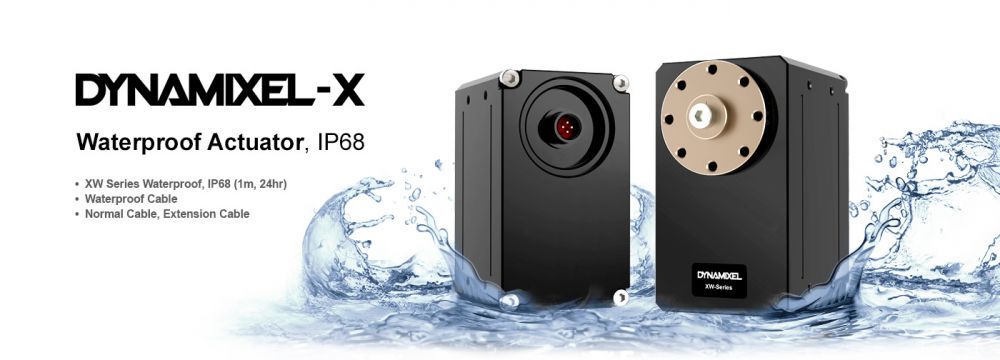
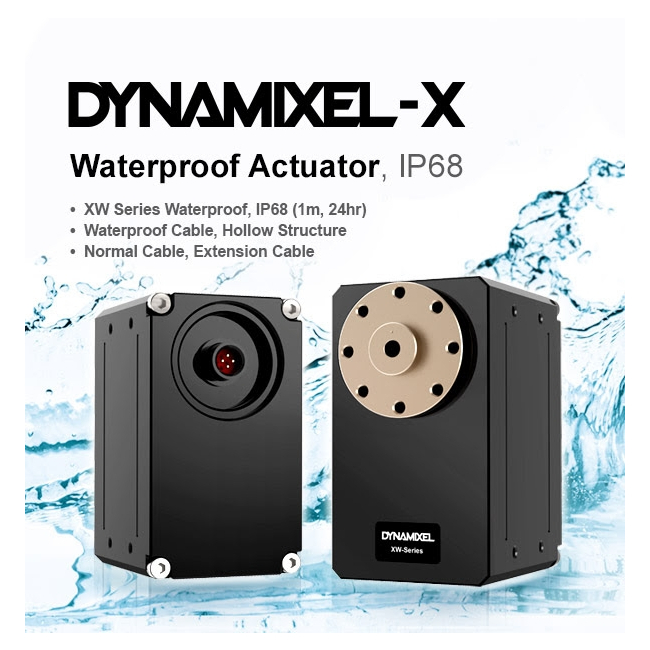
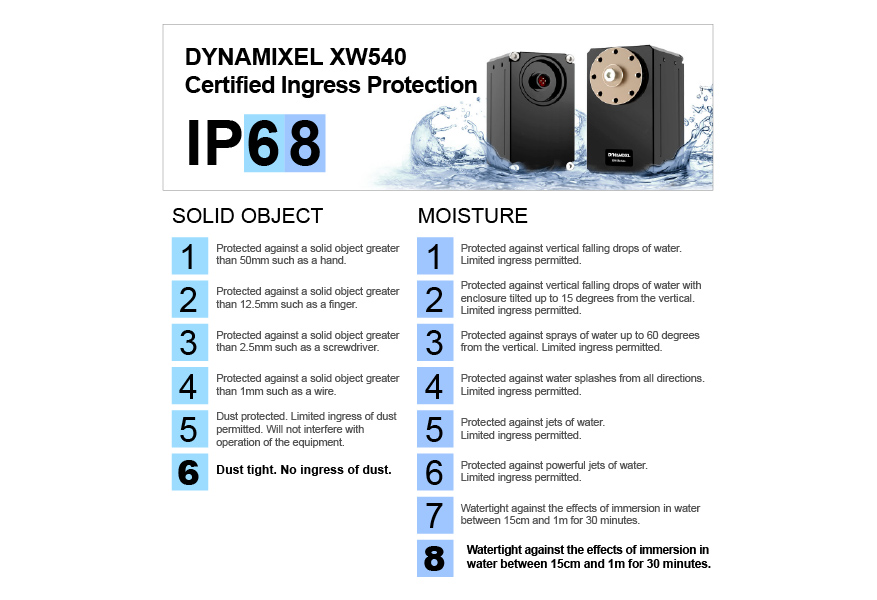
DYNAMIXEL XW series are ROBOTIS’ first line of IP Level models, featuring a certified IP68 (1m, 24hr) rating and are designed for use in wet environments, underwater, and any outdoor applications where a sealed servo is necessary.
* XW series come with separate waterproof cable and extension cable.
1. 6 Operating Modes
(Torque Control, Velocity Control, Position Control, Extended Position Control, Current based Position Control, PWM Control)
2. Profile Control for Smooth Motion Planning
3. Improved Heat Sink Featuring an Aluminum Case
4. Easy and Simple Assembly Structure
5. Energy Saving (Reduced Current from 100mA to 40mA)
6. 28.4% reduced volume compared to the MX-106
| Item | Quantity | Description |
|---|---|---|
| XW540-T140-R | 1 | DYNAMIXEL |
| HN13-N105 | 1 | Standard horn for XW540 models |
| Robot Cable-WP 1000mm | 1 | Waterproof cable |
| Robot Cable-WP 1000mm(Extension) | 1 | Waterproof cable(extension) |
| Wrench Bolt WB M2.5x5 | 16 | For frame assembly(Side hole) |
| Wrench Bolt WB M2.5x4 | 10 | For frame assembly |
| Wrench Bolt WB M3x10 | 1 | For horn assembly |
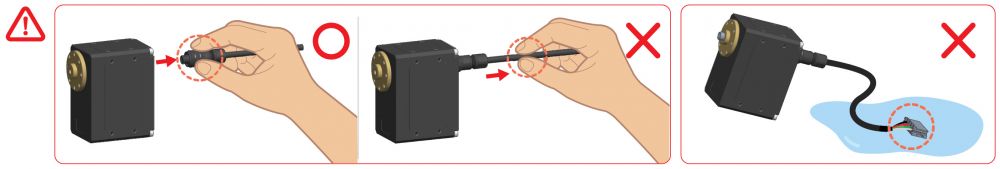
[Warning!]
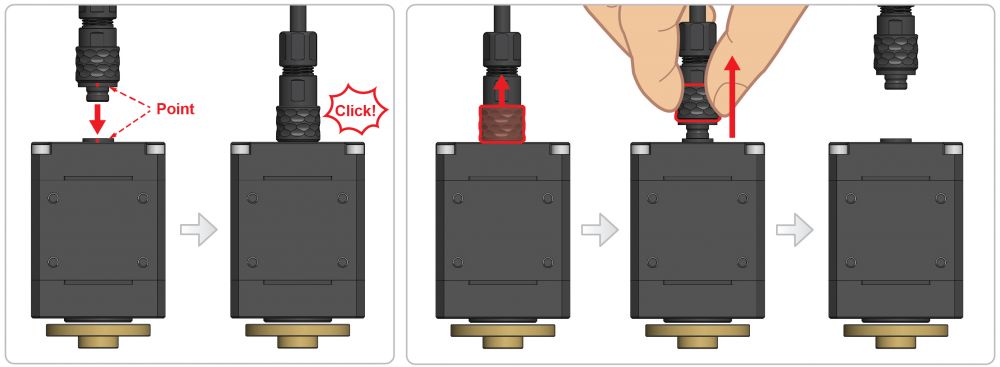
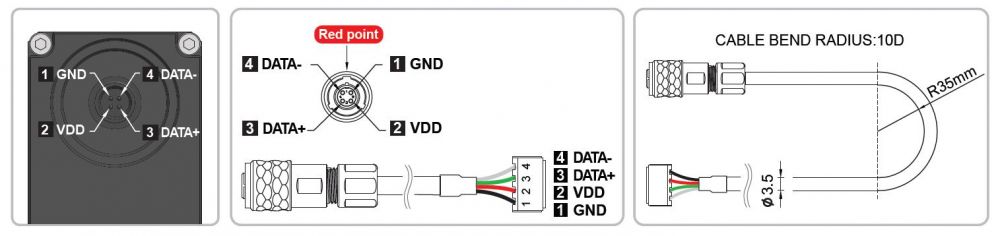
DYNAMIXEL XW series uses a waterproof cable.
One side has a waterproof connector and the other side has a JST connector.
Extension cable has waterproof connectors for both sides.
The OpenCR controller has a JST connector for direct connection, but since the OpenCM9.04 + OpenCM 485 expansion board only has a Molex connector, a conversion cable must be used by utilizing U2D2 PHB.
| Model Name | XW540-T140-R | |
|---|---|---|
| Series | DYNAMIXEL X | |
| MCU | ARM Cortex-M3 (72 [Mhz], 32 [bit]) | |
| Input Voltage | Min. [V] | 10.0 |
| Recommended [V] | 12.0 | |
| Max. [V] | 14.8 | |
| Performance Characteristics | Voltage [V] | 12.0 |
| Stall Torque [N·m] | 6.90 | |
| Stall Current [A] | 4.9 | |
| No Load Speed [rpm] | 72.0 | |
| No Load Current [A] | 0.07 | |
| Continuous Operation | Voltage [V] | - |
| Torque [N·m] | - | |
| Speed [rpm] | - | |
| Current [A] | - | |
| Resolution | Resolution [deg/pulse] | 0.0879000000 |
| Step [pulse/rev] | 4,096 | |
| Angle [degree] | 360 | |
| Position Sensor | Contactless absolute encoder (12 [bit], 360 [deg]) Maker : ams(www.ams.com), Part No : AS5045 | |
| Operating Temperature | Min. [°C] | -5 |
| Max. [°C] | 80 | |
| Motor | Coreless (Maxon) | |
| Baud Rate | Min. [bps] | 9,600 |
| Max. [bps] | 4,500,000 | |
| Control Algorithm | PID | |
| Gear Type | Spur | |
| Gear Material | Metal | |
| Case Material | Metal(Front, Middle, Back) | |
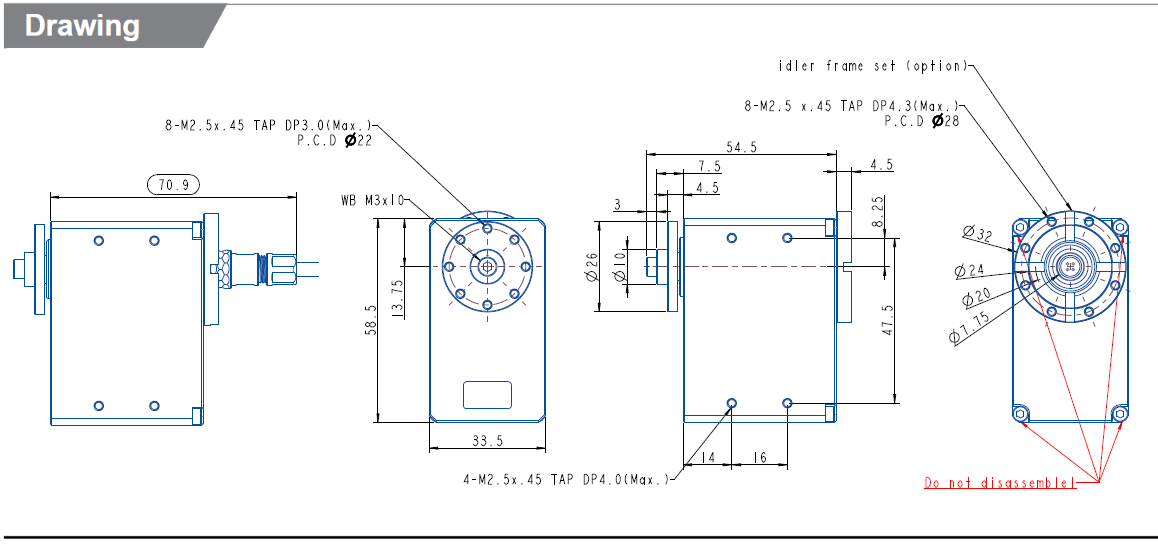
| Dimensions (WⅹHⅹD) [mm] | 33.5 x 58.5 x 45.9 | |
| Dimensions (WⅹHⅹD) [inch] | 1.32 x 2.30 x 1.73 | |
| Weight [g] | 165.00 | |
| Weight [oz] | 5.82 | |
| Gear Ratio | 145.6:1 | |
| Backlash [arcmin] | - | |
| Backlash [deg] | - | |
| Command Signal | Digital Packet | |
| Protocol Type | Asynchronous Serial Communication (8bit, 1stop, No Parity) | |
| Link (Physical) | RS-485 Multidrop Bus | |
| ID | 0 ~ 252 | |
| Feedback | Position, Velocity, Current, Realtime tick, Trajectory, Temperature, Voltage, External Port, etc. | |
| Protocol version | Protocol 1.0 Protocol 2.0(Default) | |
| Operating Mode / Angle | Current Control mode:Endless turn Velocity Control mode:Endless turn Position Control Mode:360 [deg] Extended Position Control Mode:±256 [rev] Current-based Position Control Mode:±256 [rev] PWM Control Mode:Endless turn | |
| Output [W] | - | |
| Standby Current [mA] | 40 | |
| Manufacturer | Robotis |
|---|