Currency
|

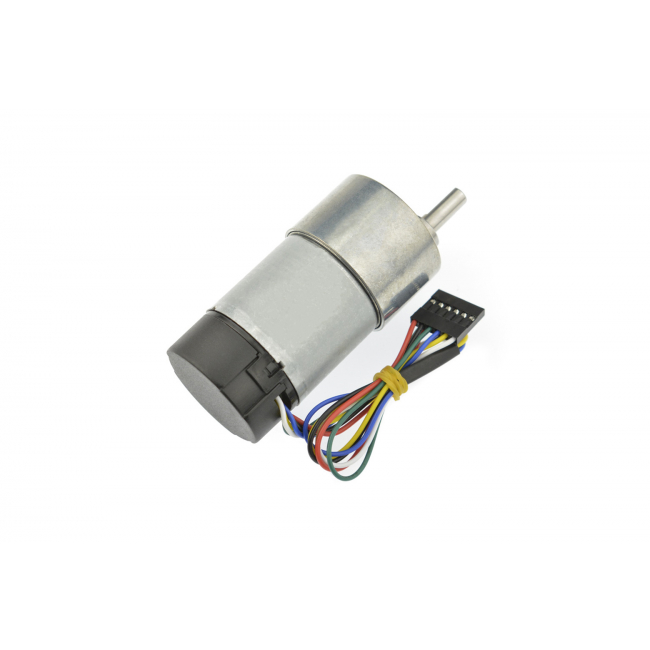
This 12V metal geared motor with encoder combines reduced-speed drive and rotation feedback for mobile robot projects. The 43.8:1 gearbox provides a nominal 251RPM no-load output, while an integrated Hall quadrature encoder supplies signals for measuring shaft rotation. A 6mm D-shaped output shaft and six M3 mounting holes support integration with a suitable wheel hub, bracket or drive mechanism. Pair this motor with a controller and appropriately rated motor driver to build feedback-based motion experiments. The motor is intended for 12V operation, and the encoder requires a separate 5V supply.
43.8:1 Metal Gearbox for Robot Drive Builds
This DC geared motor uses a 43.8:1 metal gearbox to reduce motor-shaft speed for practical mechanical output. The listed nominal no-load speed is 251RPM, supporting selection for mobile robot drive prototypes. The manufacturer specifies 18 Kg.cm stall torque and 7 A stall current, which describe the stopped-shaft condition rather than a continuous working point. Choose the mechanism, driver and power supply around the intended load instead of combining no-load speed and stall torque into an operating promise.
Hall Quadrature Encoder for Rotation Feedback
This motor includes a Hall quadrature encoder specified at 16 counts per motor-shaft revolution and 700 counts per gearbox-output revolution. A controller can use the two-phase feedback to determine direction and estimate rotational speed, then apply the readings in a motion-control program. This gives a robot project access to measured rotation alongside the motor command. The encoder operates at 5 V; confirm the feedback interface and software counting convention when connecting to the host controller.
D-Shaped Output Shaft and Six M3 Mounting Points
This geared motor provides a 0.61" long, 6 mm-diameter D-shaped output shaft for coupling to suitable mechanical hardware. Six threaded M3 holes on the face plate form a regular hexagon, with neighboring hole centers spaced 15.5 mm apart. These defined mounting features help plan a bracket or chassis around the motor. Screw insertion into the motor must not exceed 3mm, because longer engagement can contact the gears; account for bracket thickness when selecting screw length.
Wiring Diagram for 12V metal geared motor & UNO
Warning: Do not screw too far into the mounting holes as the screws can hit the gears. Manufacturer recommends screwing no further than 3mm (1/8") into the screw hole.
| Manufacturer | DFRobot |
|---|