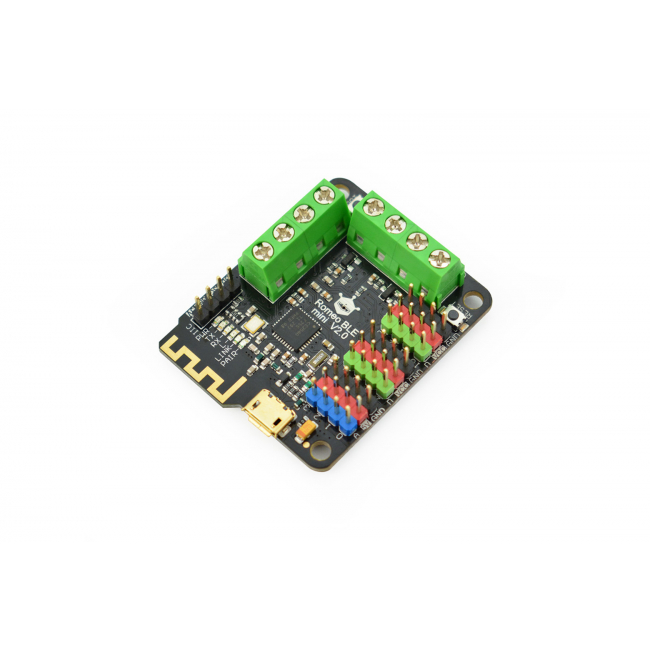
Romeo BLE mini is a simplified version of Romeo family. It inherits all functions of Romeo BLE. Moreover, IT GOT A SMALLER SIZE! Yes, you got it all. It has 8 Digital pins, 4 analog pins and integrates Bluetooth 4.0 wireless communication function. And it can easy to drive the mobile platform using two 1.2A H-bridged Motor Driver to meet the needs of small scale robots. We hope Romeo BLE mini will be a good assistant to makers. You may also check Bluetooth Microcontrollor Selection Guide to get more information.
Version Update: V2.0 has upgraded its motor driver IC, it replaces HR8833 with TB6612 motor driver chip. TB6612 has the same control logic with L298 motor driver. The code will be compatible with Romeo robot control board. And it finally breakouts 2 interrupt pins now! You can connect encoders to make PID motor control.
Romeo BLE mini Projects:
How To Make an Arduino compatible Bluetooth Tank with Custom Android Application (V1.0)
How to Build a BB-8 Robot
How to Build a Smartphone-Controlled Robot for Arduino In Only 1 hour
How to make a Wobbly Penguin Robot for Arduino
Features
Support Gravity-3Pin interface, color-coded, compatible with servos and Gravity sensors & modules
Support external power supply automatically switch, can simultaneously USB and external power supply
Support wireless download program / wireless communication function
Support mobile phone APP control
Two-way H-bridged Motor Driver
Support servo external power input
Supports AT commands to configure BLE
Support serial transmission
Support master and slave switch
Specification
BLE chip: TI CC2540
Transmission distance: 30m (open area)
Microprocessor: ATmega328P
Board selection: Arduino UNO
Flash: 32 KB (ATmega328P) of which 0.5 KB used by bootloader
SRAM2: KB (ATmega328P)
EEPROM: 1 KB (ATmega328P)
Clock Frequency: 16 MHz
Digital I/O Pins: 8
PWM Digital I/O Pins: 4 (D3, D9, D10, D11)
Analog Input Pins: 4
Output current: 1.2A single-channel continuous drive current