Currency
|

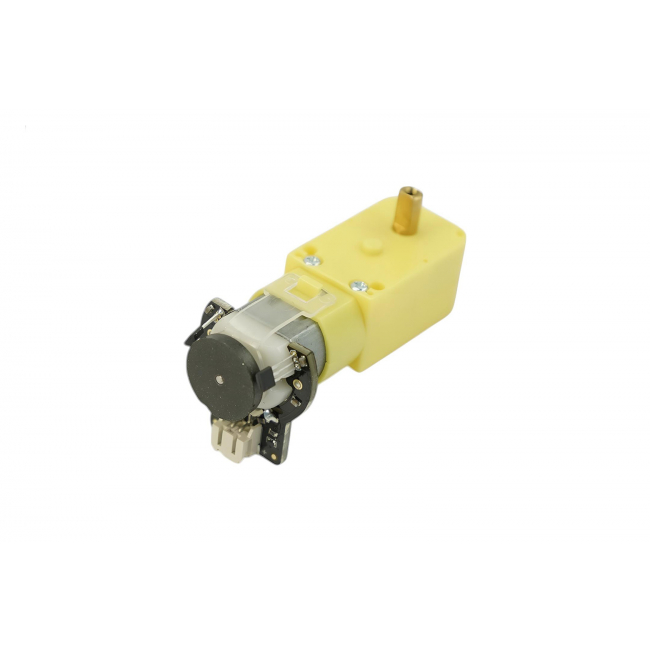
This 120:1 TT geared motor with encoder adds motion feedback to mobile robot projects, helping a controller work with measured rotation rather than a motor command alone. The gearbox provides 160 rpm no-load speed at the rated 6V, while the integrated quadrature encoder supports speed and direction sensing. Pair this motor with an Arduino controller and a suitable motor driver to develop PWM speed control or closed-loop PID experiments. A copper output shaft, embedded thread and reinforced connector support practical assembly, and separate motor and encoder cables are included for integration.
120:1 Reduction for Mobile Robot Drive Projects
This TT motor combines a compact DC motor with a 120:1 gearbox for lower-speed output suitable for mobile robot mechanisms. The listed no-load speeds are 160 rpm at 6V and 60 rpm at 3V, providing reference points for selecting a supply and planning motion. Rated torque is 0.2kgf.cm, while maximum stall torque is 0.8kgf.cm. Actual operating speed depends on the load, so the no-load figures should not be treated as guaranteed wheel speeds.
Quadrature Feedback for Speed and Direction Control
This geared motor's integrated quadrature encoder provides two-phase feedback that a controller can use to determine rotation direction and estimate speed. The manufacturer lists 8 pulses per motor revolution and 960 pulses per gearbox output revolution through the 120:1 reduction. The resulting feedback supports closed-loop control experiments, with software calculating motion and adjusting the driver's PWM command. Pulse counts must match the chosen decoding method; counting signal edges can change the number recorded by the program.
Copper Shaft and Separate Connection Cables
This TT motor features a copper output shaft with an embedded thread and a reinforced connector, supporting repeated assembly in robotics projects. The supplied JST 2-pin motor cable and JST 4-pin encoder cable separate motor power from feedback wiring. The encoder interface is compatible with DFRobot's Gravity interface, while the motor still requires an appropriate driver. Follow the separate voltage requirements when wiring: the motor accepts 3~7.5V, and the encoder requires 4.5~7.5V.

Wiring Diagram of 120:1 TT geared motor and Arduino
| Manufacturer | DFRobot |
|---|