Currency
|

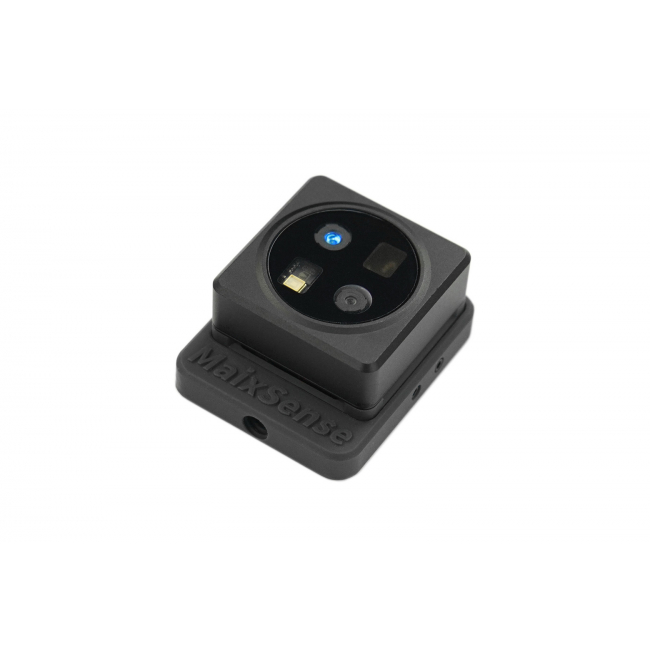
This RGB-D 3D ToF sensor camera brings color images and depth data together for close-range robotics and 3D vision development. Depth imaging at 320 x 240@30fps and RGB imaging at 800×600@30fps support scene observation across the stated 0.2~2m detection range. Connect through USB to preview depth, IR, RGB and point-cloud views in a web browser, then continue development with ROS1/ROS2 integration packages or the Python SDK. An integrated IMU complements the camera hardware. The kit includes connection cables, a tripod stand and a cooling fan, providing a practical starting point for exploring RGB-D data.
Color and Depth for Close-Range 3D Vision
This ToF camera combines RGB imagery with depth measurements, giving a project both visual appearance and spatial information. Point-cloud data supports exploring object shape and scene geometry, while the RGB stream adds color information for visualization. The stated detection distance is 0.2~2m, making this module a candidate for close-range robot vision and tabletop experiments. The depth and RGB fields of view differ, so application processing should account for their separate viewing areas.
Browser Preview Through a USB Connection
This RGB-D camera uses a USB virtual-network data channel and web service to make the sensor views accessible in a browser. Preview depth, infrared, RGB and point-cloud data before developing application code, including colorful 3D visualization. Linux supports the documented connection without installing an additional camera driver. Windows setup may require the supplied RNDIS driver and installation procedure. This preview workflow provides a straightforward way to check the scene and connection before integrating the camera into a larger project.
ROS and Python Resources for Application Development
This 3D camera supports ROS1 and ROS2 with integration packages and example code, alongside a Python SDK for working with the acquired data. These resources provide a starting point for SLAM experiments, robotic grasping, dimensional analysis and interactive vision prototypes. The camera supplies sensing data; the finished application depends on the selected algorithms, host processing and system integration.
Interfaces of the RGB-D camera
What is Time-of-Flight (ToF) technology and GB-D 3D ToF Sensor Camera?
Time-of-Flight technology is a method used for distance measurement. It involves calculating the distance between an emitter and a reflector by measuring the "flight time" of signals such as ultrasonic waves, microwaves, or light.
RGB-D 3D ToF Sensor Camera is a type of camera that combines RGB (Red, Green, Blue) and depth sensors. It is capable of providing both RGB images and depth images. RGB images capture the color information of the scene, while depth images provide the depth information of objects in the scene relative to the camera. ToF sensors are employed for this purpose, with the most commonly used ones being infrared or laser rangefinders. Variations in distance between objects are captured by the module, and these differences are displayed as cooler or warmer colors. The color tones shift with the mapping of distance, with warmer tones (orange-red) representing closer distances and cooler tones (blue) indicating greater distances.
Time-of-Flight (ToF) technology of the RGB-D camera
Selection Guide
| Manufacturer | DFRobot |
|---|