Currency
|

From £2,135.36 £1,779.47
To £8,822.36 £7,351.97
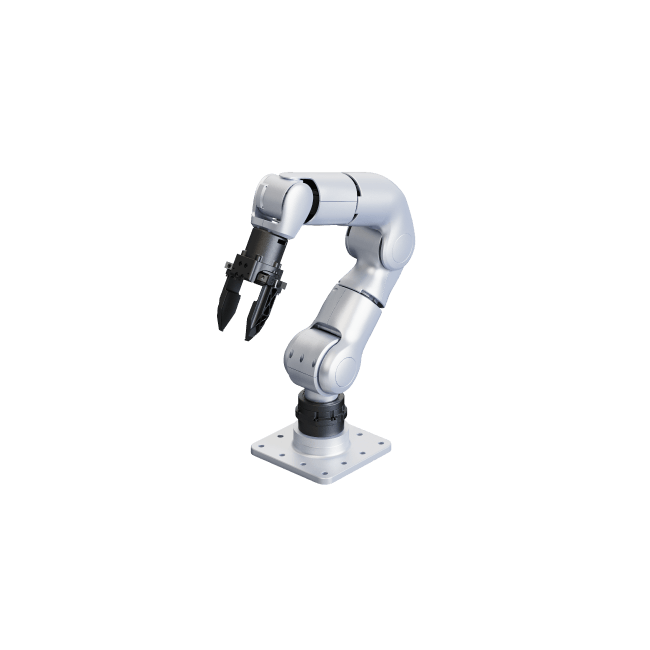
Bionic 7-Axis Dexterous Robotic Arm
High-precision motion, flexible manipulation and intelligent control. A compact robotic arm designed for research, education and advanced automation applications.
The Unitree R1-7A combines seven coordinated axes, high-rigidity construction and advanced force feedback to deliver flexible and precise robotic manipulation. Its compact design and open development interfaces make it a versatile platform for experimentation and research.
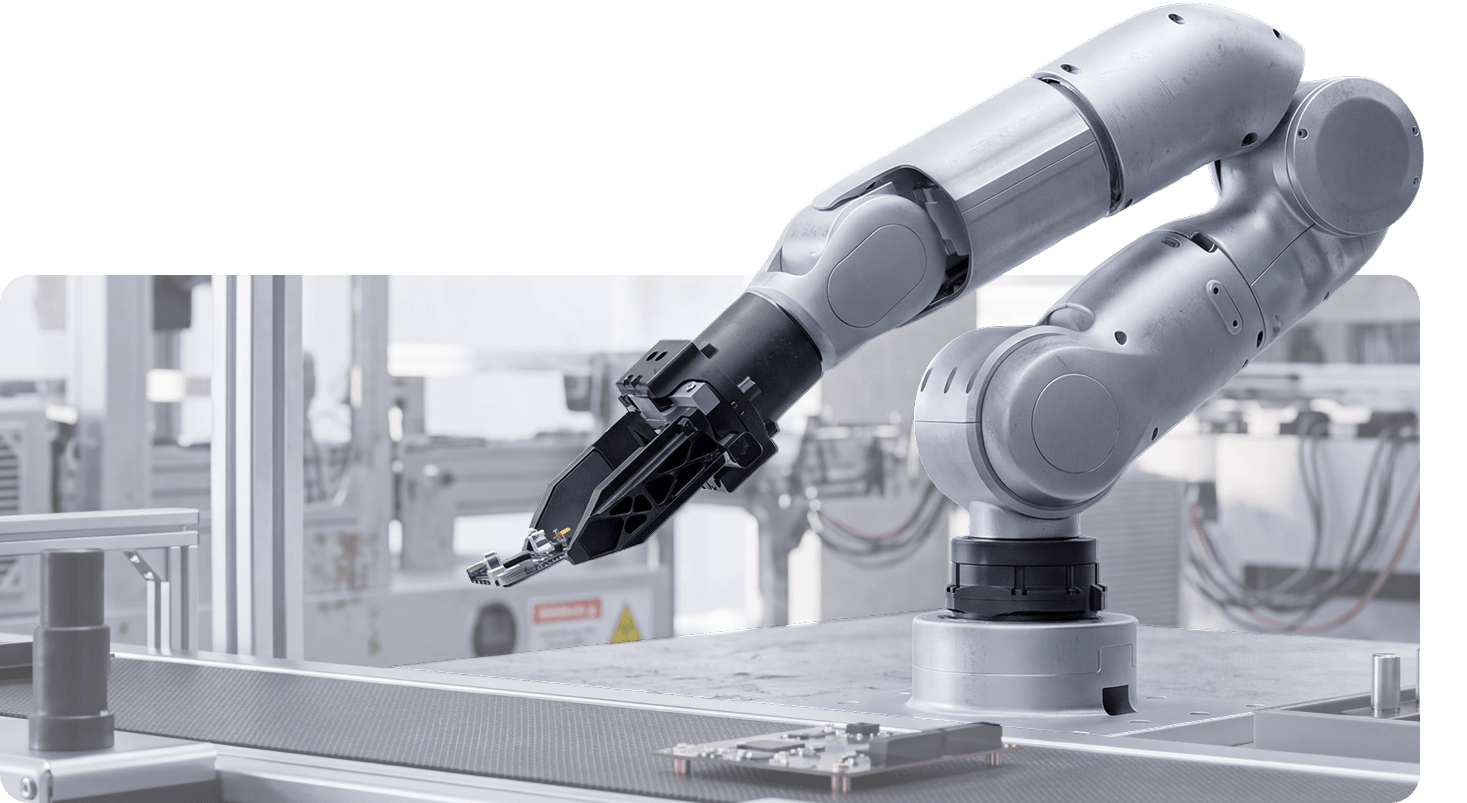
Seven coordinated joints provide flexible, human-inspired movement. The additional axis enables reacharound operations in confined spaces and complex working environments.
A combination of metal and high-strength engineering plastics balances lightweight construction with structural rigidity, helping maintain stability during extended operation.
Weighing approximately 5.5 kg, the R1-7A offers a desktop-class robotic manipulation platform with a compact footprint and convenient integration.
Integrated force feedback and collision detection support more responsive control and interaction with objects and the surrounding environment.
Designed for further development, with control programs and interfaces planned for iterative open-source release. Supports rapid end-effector replacement.
Supports position and force control, providing flexibility for different manipulation strategies, research projects and automation tasks.
The seven-axis architecture provides additional freedom when planning complex movements. The arm can adjust its end-effector orientation from multiple angles while navigating around obstacles and working in restricted spaces.
Seven independently controlled joints provide flexible positioning and orientation.
Supports force-based manipulation and more responsive interaction.
Integrated collision detection helps identify contact during operation.
Two control approaches for different manipulation requirements.
From laboratory experiments to complex manipulation tasks, the R1-7A provides a flexible platform for exploring robotic capabilities.
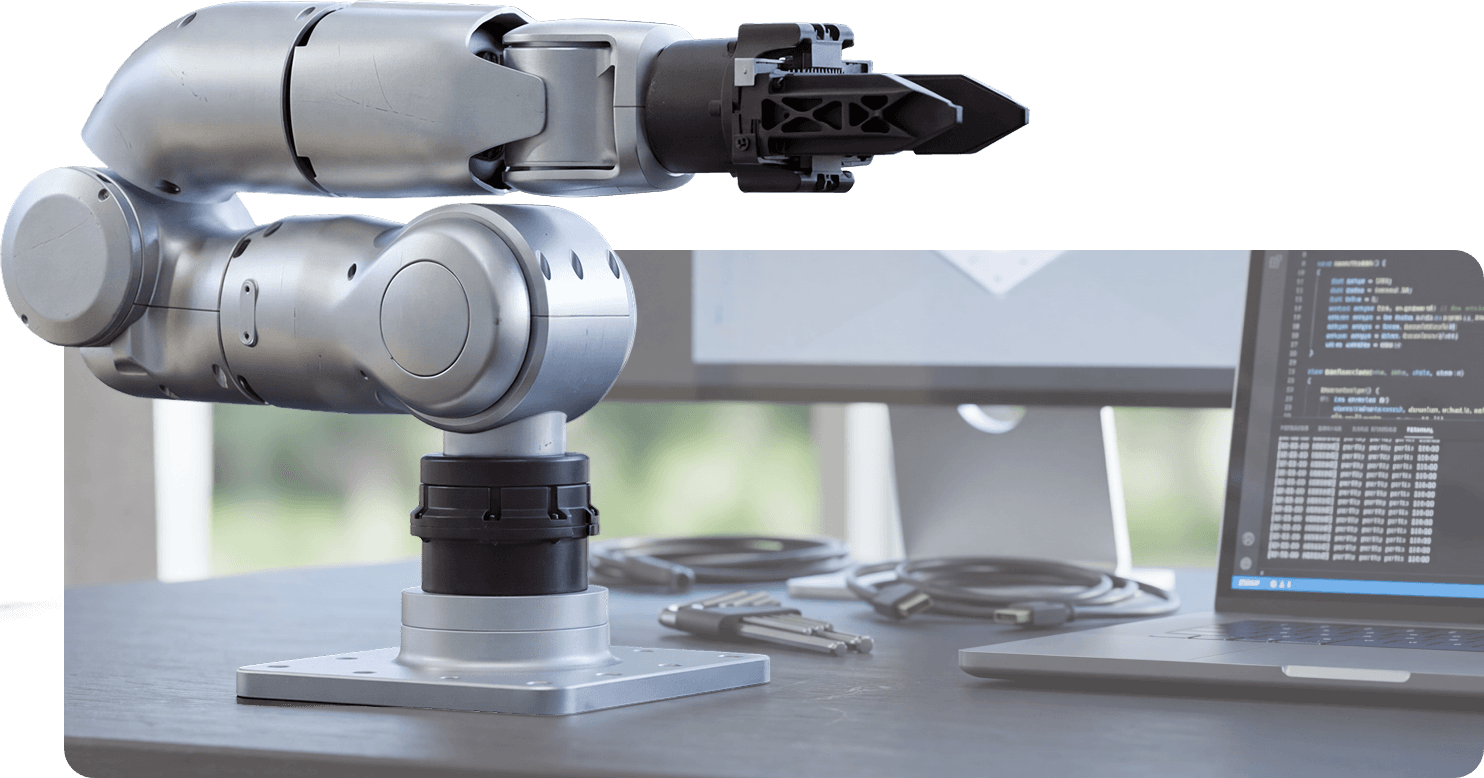
Optimised for scientific research and educational environments, the R1-7A offers a practical platform for studying robotic manipulation, motion planning, force control and human-robot interaction.
Two robotic arms can work together to perform coordinated operations, including material sorting, object handling and assembly tasks.
Explore service robotics applications through manipulation tasks that replicate everyday activities and object interaction.
Investigate how robotic systems can use flexible manipulation capabilities to perform maintenance and interaction tasks on their own platforms.
The compact design and interchangeable end-effector interface make the R1-7A suitable for integration into a variety of laboratory and research environments.
The R1-7A is designed to support robotics development, software experimentation and integration into custom research platforms.
24V–60V power requirement
XT30 + CAN485 interfaces
Ubuntu
Position control and force control
Unitree R1-7A Bionic Robotic Arm
| Specification | Unitree R1-7A |
|---|---|
| General | |
| Model | R1-7A Robotic Arm |
| Degrees of Freedom | 7-axis |
| Weight | Approx. 5.5 kg |
| Maximum Payload | 2 kg |
| Maximum Reach | 650 mm (with dexterous hand) |
| Electrical & Control | |
| Power Requirement | 24V–60V |
| Interfaces | XT30 + CAN485 |
| User Operating System | Ubuntu |
| Control Interface | Position / Force Control |
| Force Feedback | Yes |
| Collision Detection | Yes |
| Joint Configuration | |
| Joint 1 | J1 / 6010 |
| Joint 2 | J2 / 6010 |
| Joint 3 | J3 / 6014 |
| Joint 4 | J4 / 6014 |
| Joint 5 | J5 / 6014 |
| Joint 6 | J6 / 5010 |
| Joint 7 | J7 / 5010 |
| Joint Motion Range | |
| Joint 1 | -156° to +156° |
| Joint 2 | 0° to 180° |
| Joint 3 | -20° to +200° |
| Joint 4 | 0° to 180° |
| Joint 5 | -130° to +130° |
| Joint 6 | -30° to +30° |
| Joint 7 | -90° to +90° |
| Joint Torque Range (as published) | |
| Joint 1 | -2.7227 to +2.7227 |
| Joint 2 | 0 to 3.1416 |
| Joint 3 | -0.3491 to +3.491 |
| Joint 4 | 0 to 3.1416 |
| Joint 5 | -2.269 to +2.269 |
| Joint 6 | -0.524 to +0.524 |
| Joint 7 | -1.571 to +1.571 |
| Maximum Joint Speed | |
| Joint 1–7 | >180°/s per joint |
Specifications are based on Unitree's published product information. Parameters should be verified through actual testing according to application requirements. Robotic arm accuracy and positional-control performance may vary depending on test conditions and control algorithms. Torque range units are not specified in the published table.
A compact, versatile and development-oriented robotic arm bringing advanced seven-axis manipulation to research, education and intelligent automation.
| Manufacturer | Unitree |
|---|